Tech & Builds
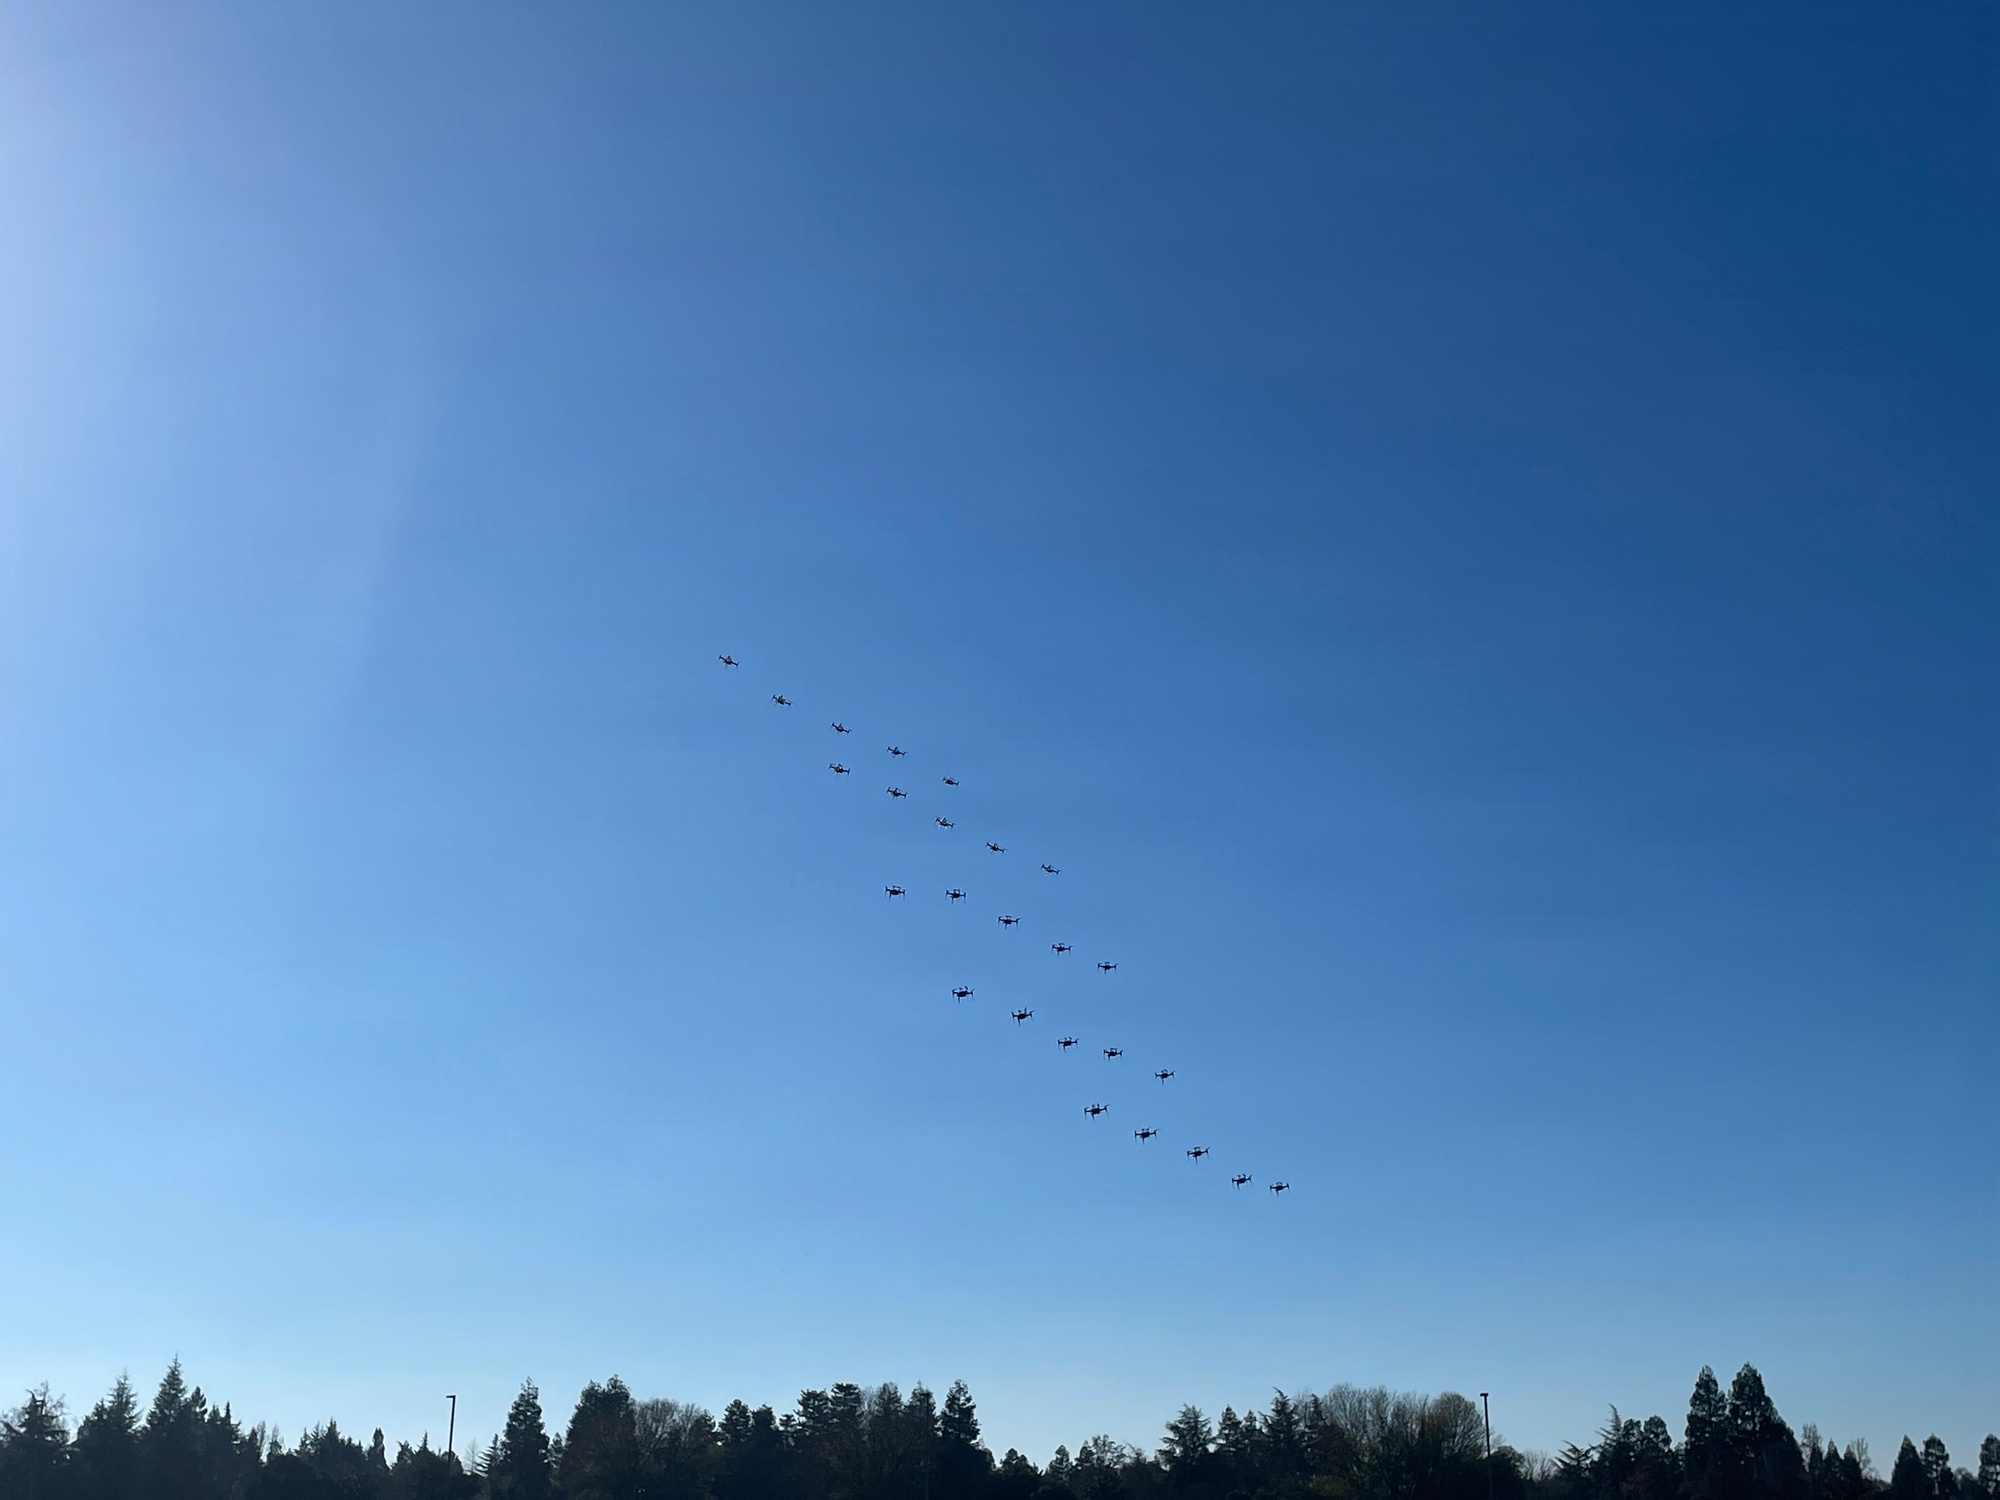
A Chinese Three-Drone Swarm Maps a Park With No Pilot and No Ground Station, and the Authors Withhold the Code
Tongji-led researchers' ESCAPE framework lets lidar quadrotors split up and map unknown spaces with every decision made on board, using a collision risk score instead of trusting stale shared trajectories. The team says the code is not available for public release.
Read the story →